Relations · failure Kimi K3.1 Pro
Kimi takes one overhead look, slides the clock beside the candle and stops
Failed in 3 tool calls: 1 look (0 close, at 20 degrees or lower; 0 at 5 degrees), 1 edit or other call.
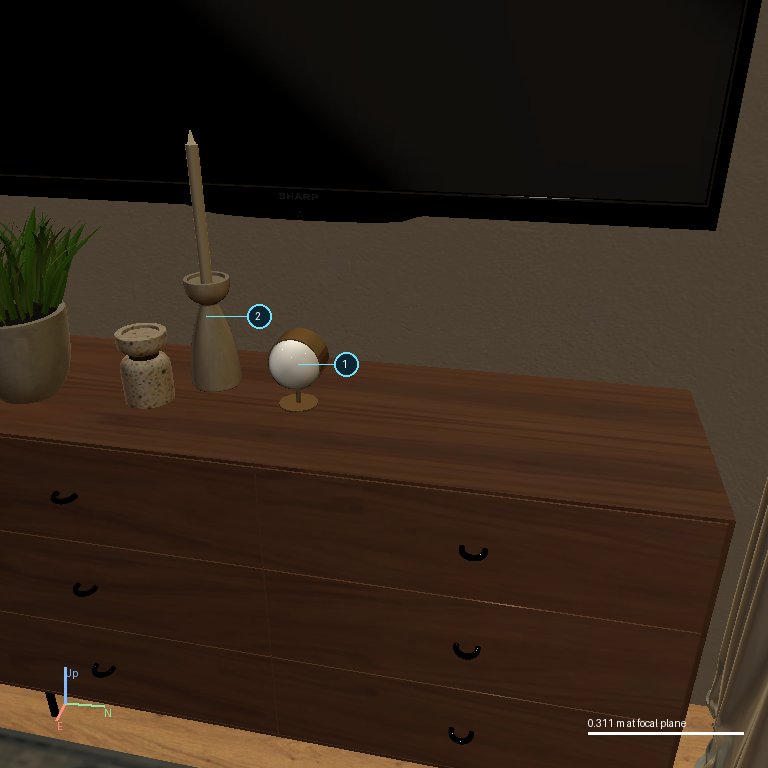
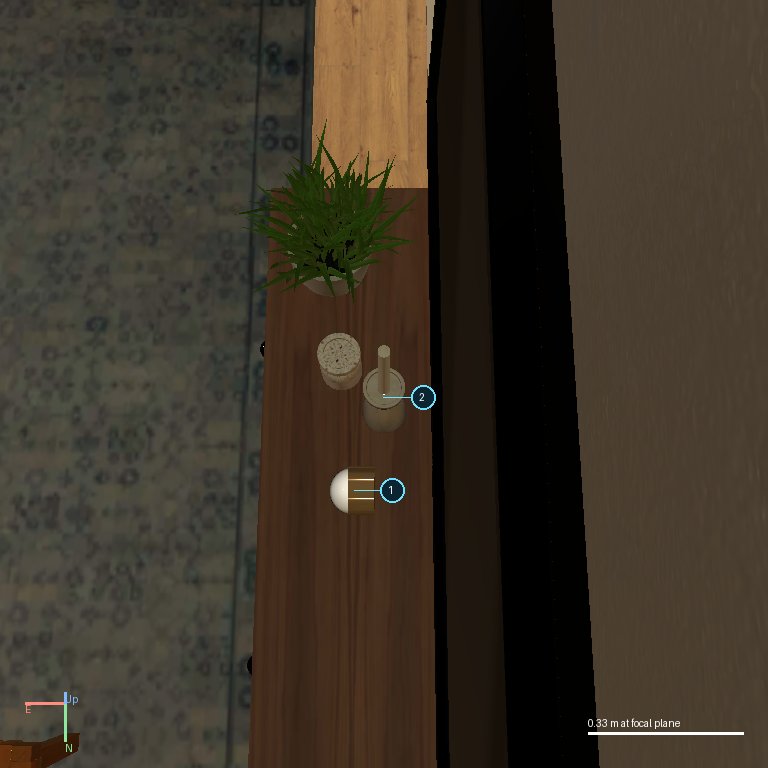
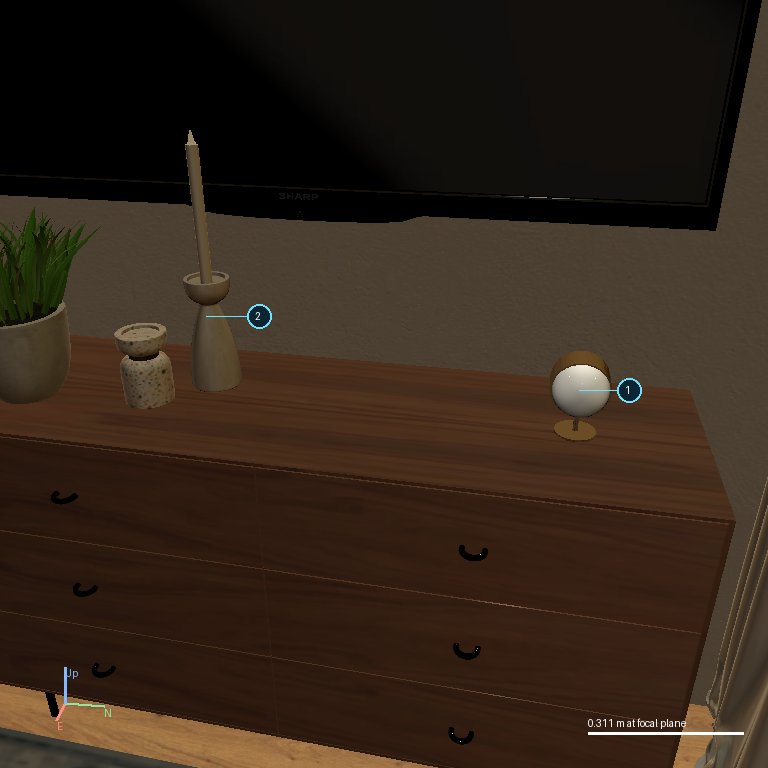
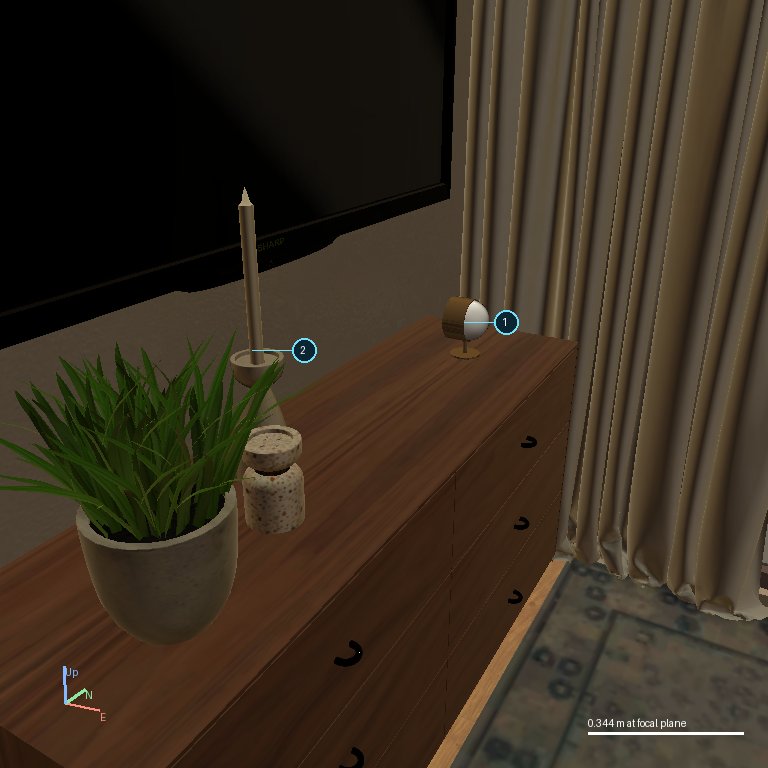
The task: move the alarm clock (1) so it is in front of the candle (2) as seen in View 1, i.e. between the candle and the View-1 camera. The View-1 camera stands to the east of the dresser, but Kimi read the compass as putting it to the north-east and never took a view from that side to check. Its only look was an overhead view from the north. It then made one move, 0.55 m south along the dresser, which put the clock next to the candle in the same row instead of toward the camera. Kimi finished right away. In the final View 1 the clock stands beside the candle, 58.6 degrees off the 'front' direction. GPT-6 solved the same episode in 7 steps: it slid the clock level with the candle, then moved it 0.12 m east toward the camera (1.1 degrees off).
Checks not met: hssd_view_relation:object_1
- Step 1: The only look: an overhead view from bearing 0 (north). It shows the dresser lengthwise but not what 'in front' means from View 1.
- Step 2: Moves the clock 0.55 m south along the dresser; its reasoning places the camera north-east, though it is due east (bearing about 78).
- Step 3: Finishes with no new view; it judged the re-rendered View 1 ('lower and right, so yes closer') when the clock was actually beside the candle.
the instruction
Move the alarm clock labelled 1 (object_1) so that it is in front of the candle labelled 2 (object_2), as seen in View 1. Keep it on the chest of drawers.
Each box is one tool call. Left: the images that call returned, which are what Kimi K3.1 Pro looked at before its next call (a camera call returns the view it asked for; an edit returns fresh images of the result). Right: its visible text if any, the call and its text result. Hidden reasoning is not shown. Images are the files saved during the run, re-encoded as JPEG; click for full size.
Step 1: observe_scene
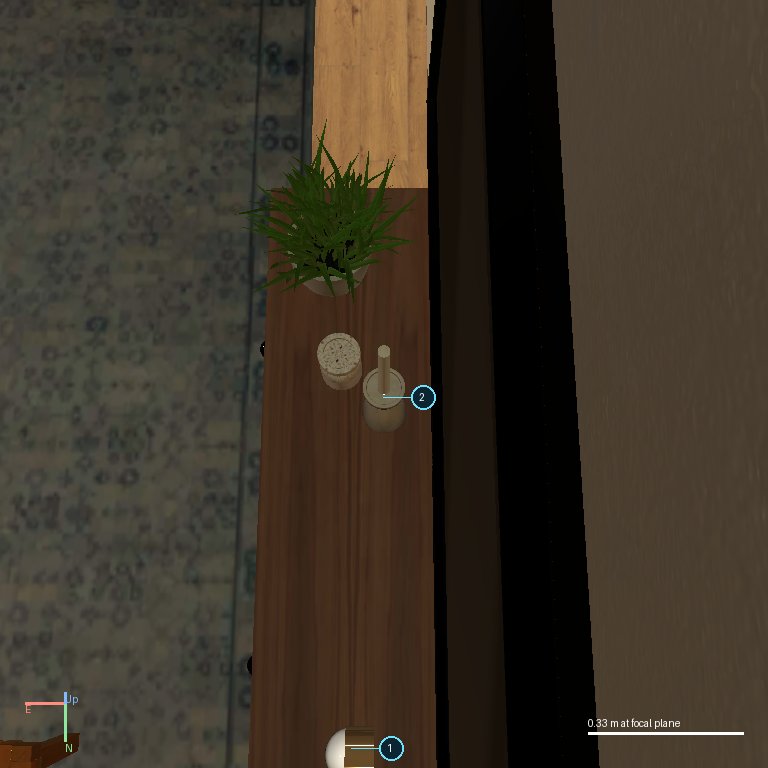
Step 2: move